Read the physical world.
The custom infrared array turns the line into a position signal. Sensor placement and electronics shape everything downstream.
CHRISTCHURCH, NEW ZEALAND
I’m Jules, a mechatronics engineering student building at the intersection of embedded systems, electronics and software.
University of Canterbury
Incoming Integrated Operations Engineering Intern · Rocket Lab
01 / SELECTED WORK
From a custom circuit to a complete robot.
A closer look at the decisions, tools and
iterations behind the projects.
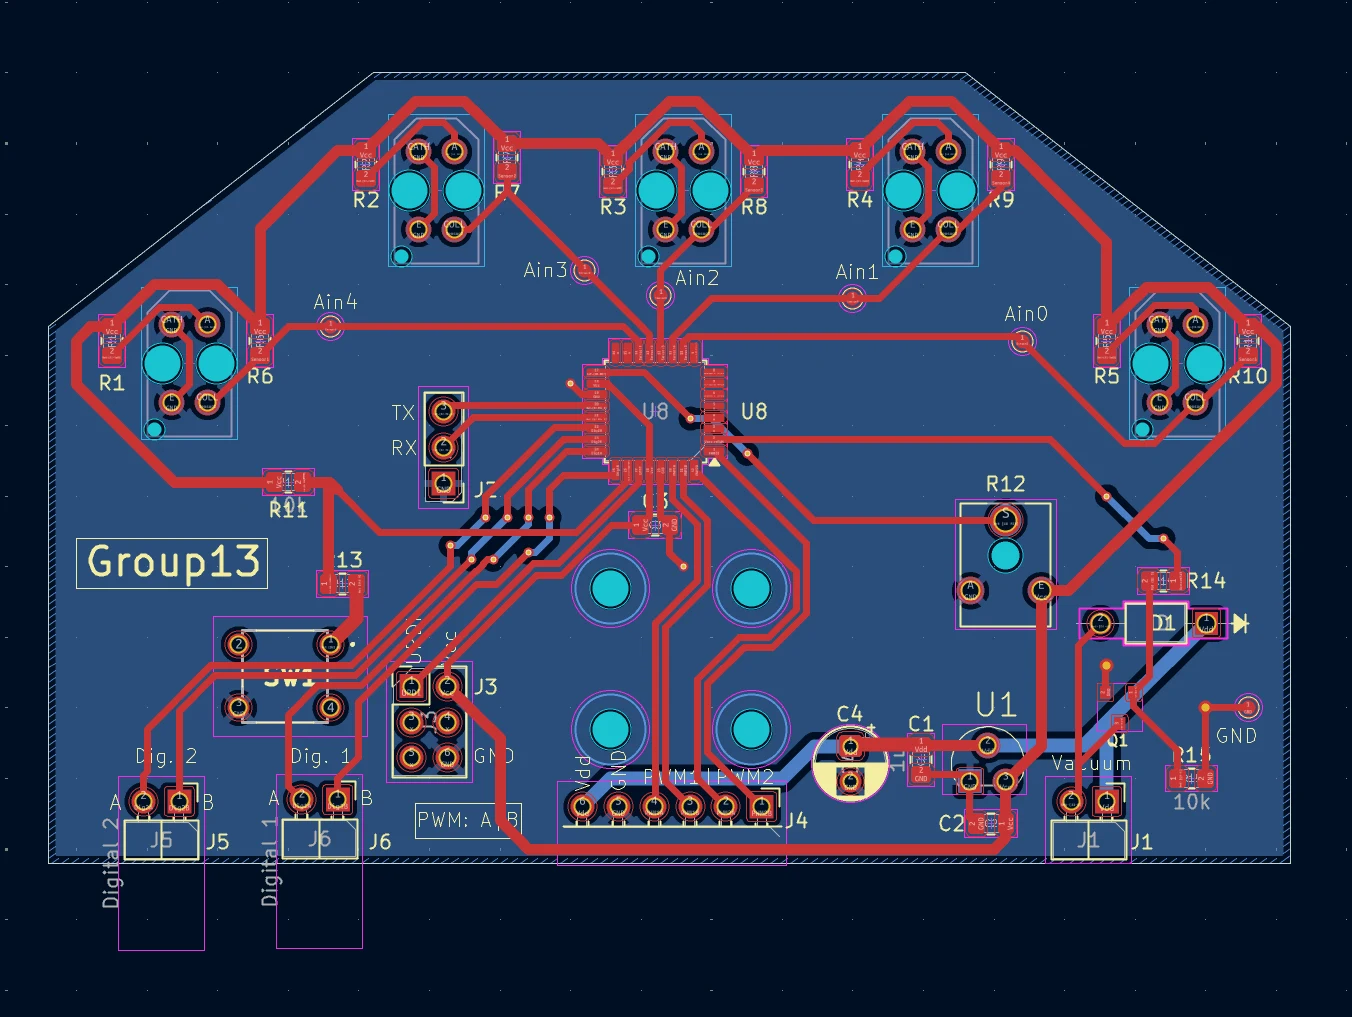
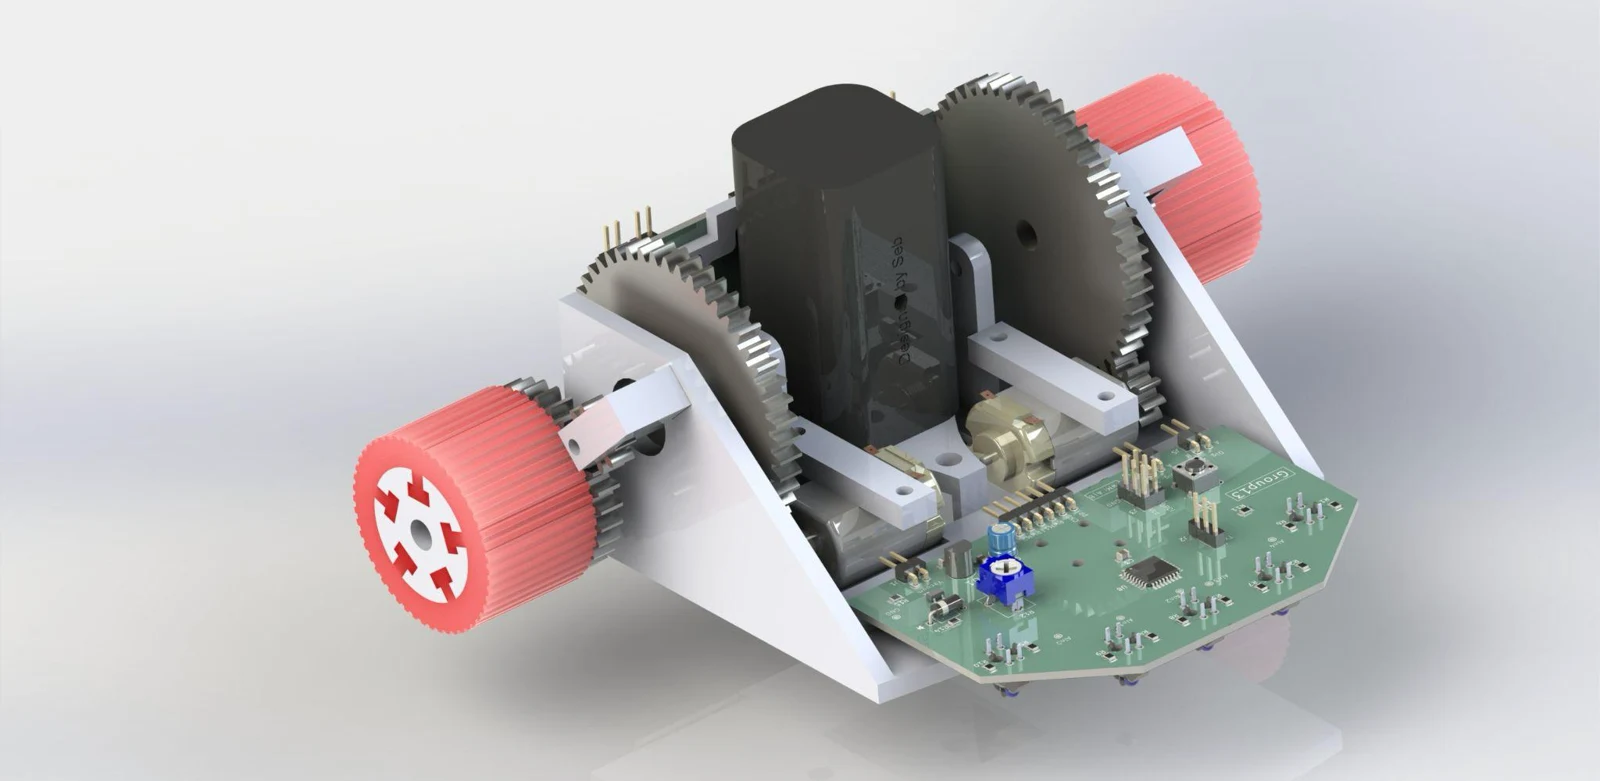
GROUP 13 · ENMT221 · 2025FROM CIRCUIT TO CLOSED LOOP
Custom PCBs, bare-metal control and a wireless Bayesian PID tuning workflow.
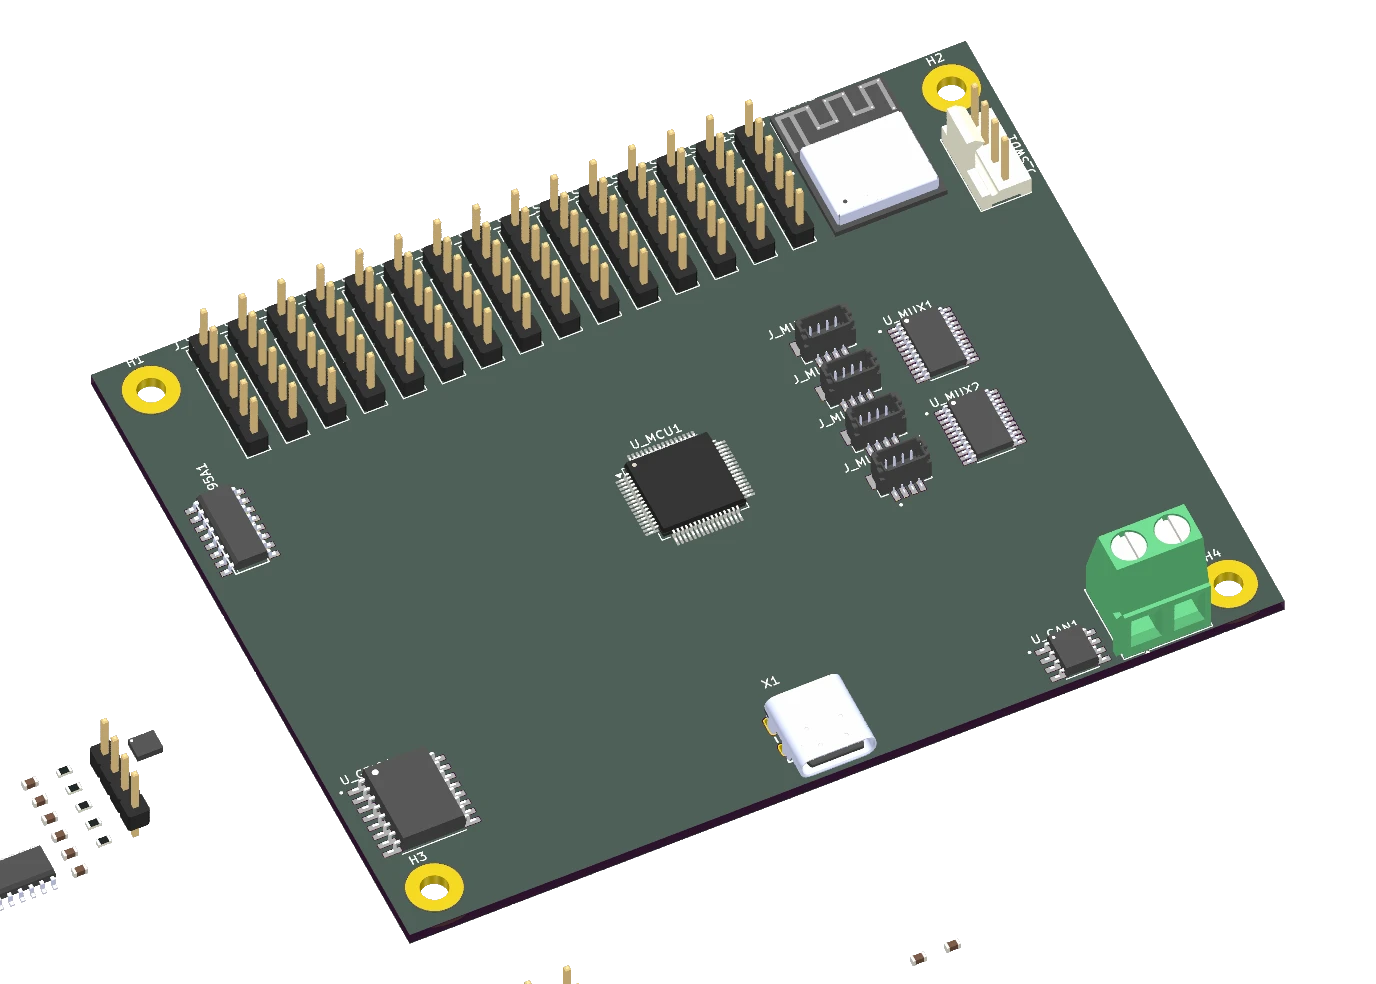 KICAD DESIGN VISUALISATION
A FOUNDATION FOR ROBOTS
An integrated STM32 / ESP32 robotics carrier platform for motors, sensors and connectivity.
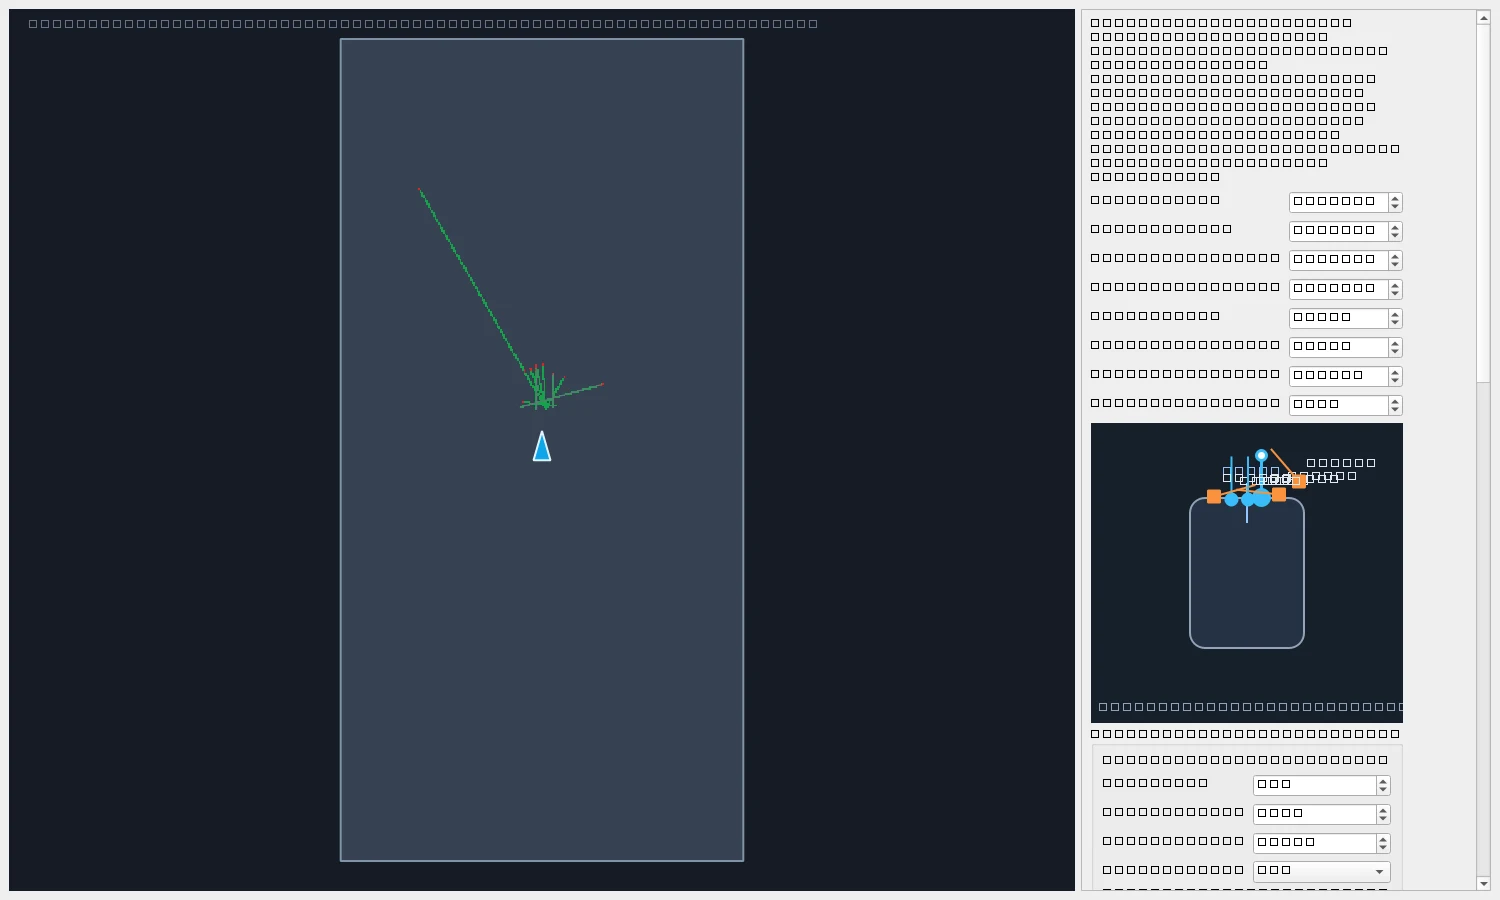 LOCAL MAPPING & TELEMETRY
MAKE THE ROBOT OBSERVABLE
Teensy firmware, live diagnostics, sensor mapping and route planning for an autonomous robot.
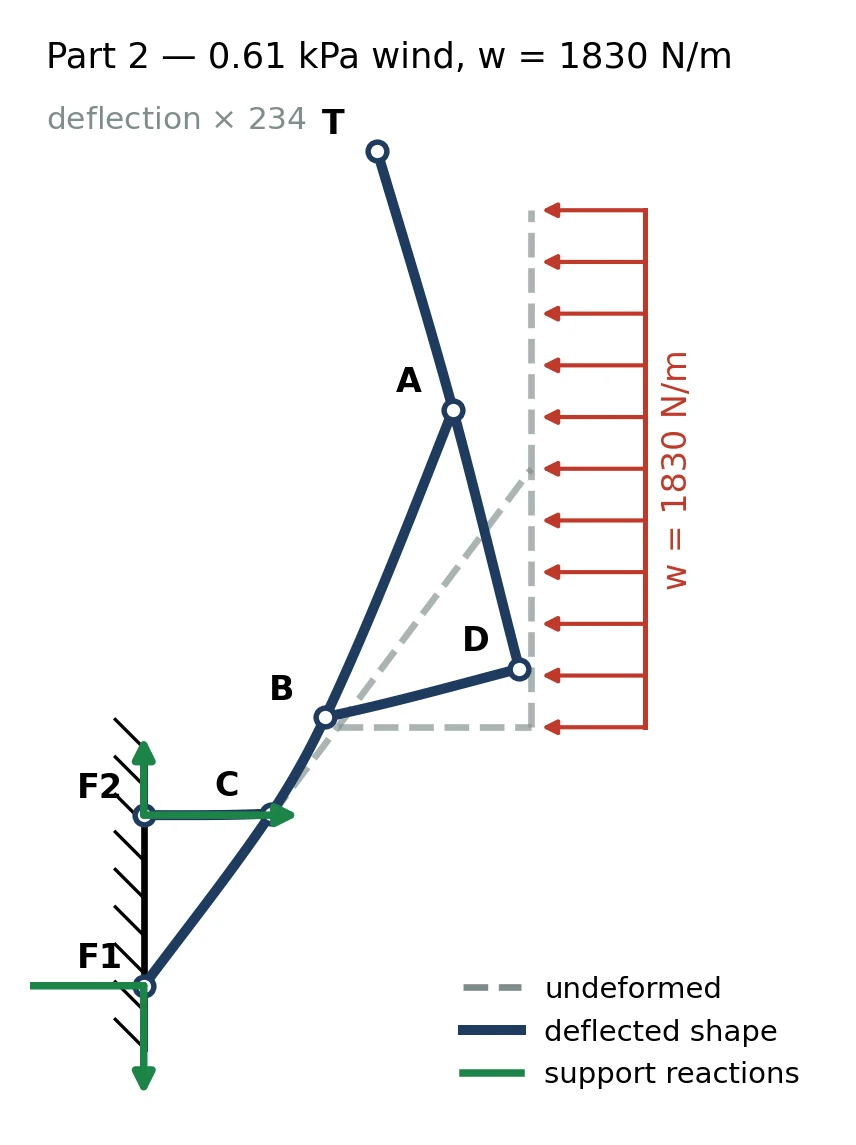
FIRST PRINCIPLES, MADE INTERACTIVE
A 2D direct-stiffness engine with visual modelling, deflected shapes and transparent worked solutions.
A STATE FOR EVERY DECISION
Five floors, encoder positioning and direction-aware scheduling on an Omron PLC.
MAKE MOTION DELIBERATE
Full mechanical system design. Explore the motion concept ahead of the project imagery.
SMALL SYSTEM. COMPLETE EXPERIENCE.
Interrupt-driven sensing, cooperative scheduling and a thoughtful OLED interface.
University team projects and collaborative hardware work are credited in each case study.
FOLLOW THE SIGNAL / SCROLL TO EXPLORE
The custom infrared array turns the line into a position signal. Sensor placement and electronics shape everything downstream.
Bare-metal firmware processes the sensor error and computes the motor response. The control loop connects the mathematics to real hardware.
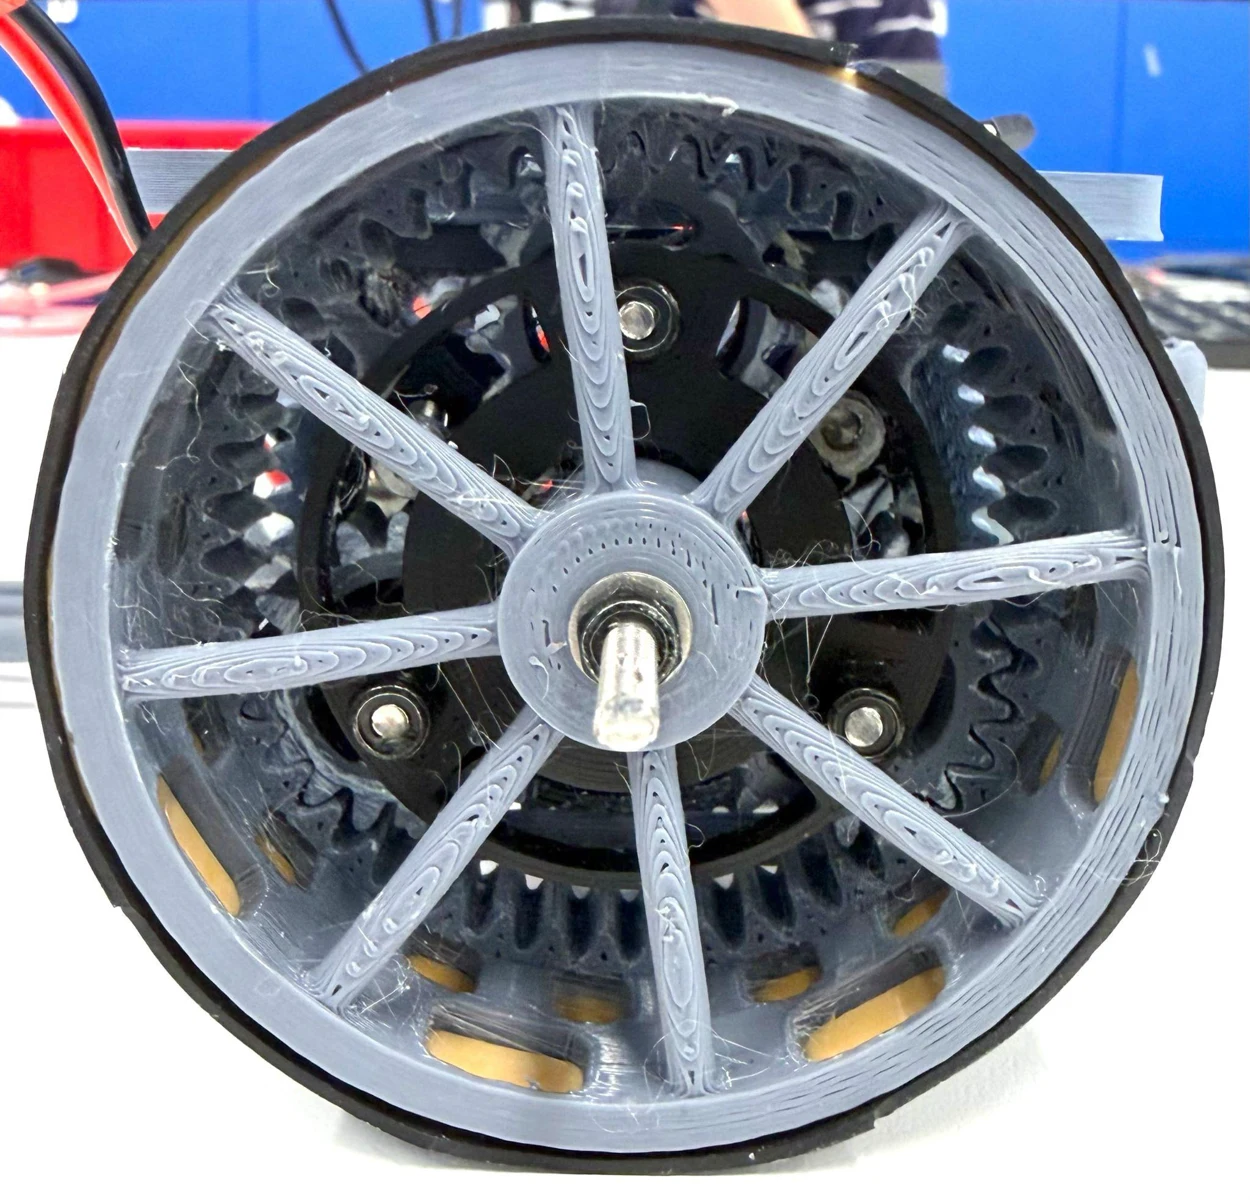
The H-bridge and drivetrain put the command on the track. PCB design, gear geometry and mechanical integration are part of the same system.
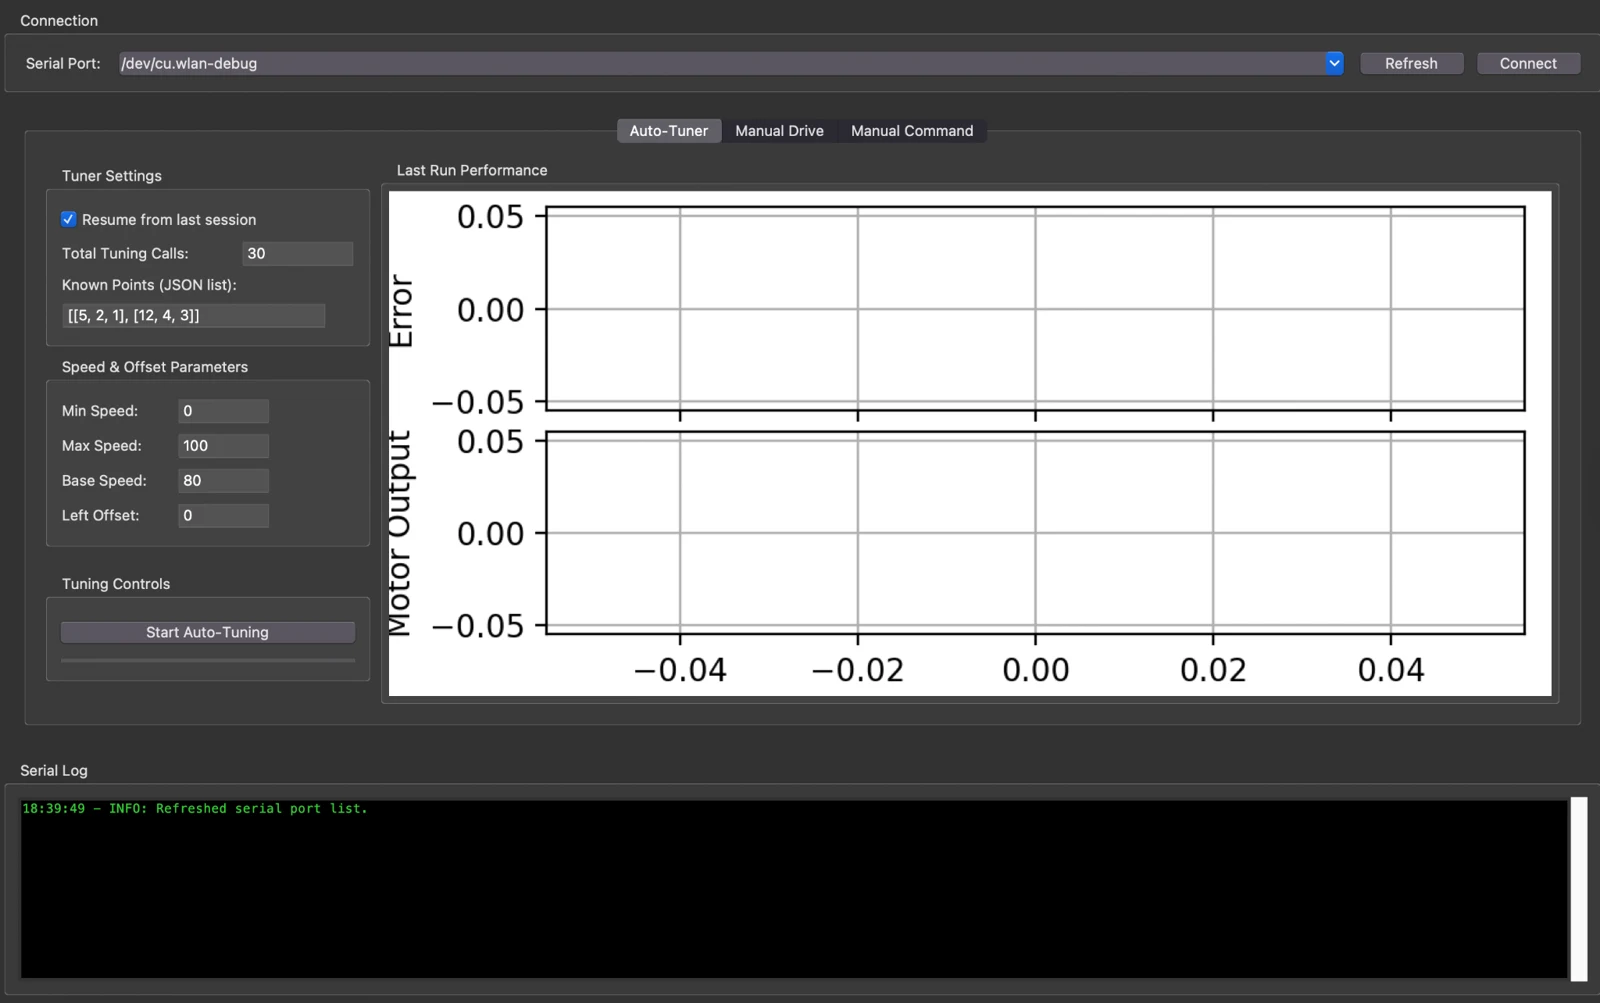
Wireless telemetry closes the development loop. The Python Bayesian tuner uses the robot’s response to explore PID gains.
 Explore the whole build ↗
02 / ENGINEERING YOU CAN TOUCH
Real calculations. Real geometry.
Get your hands on the engineering.
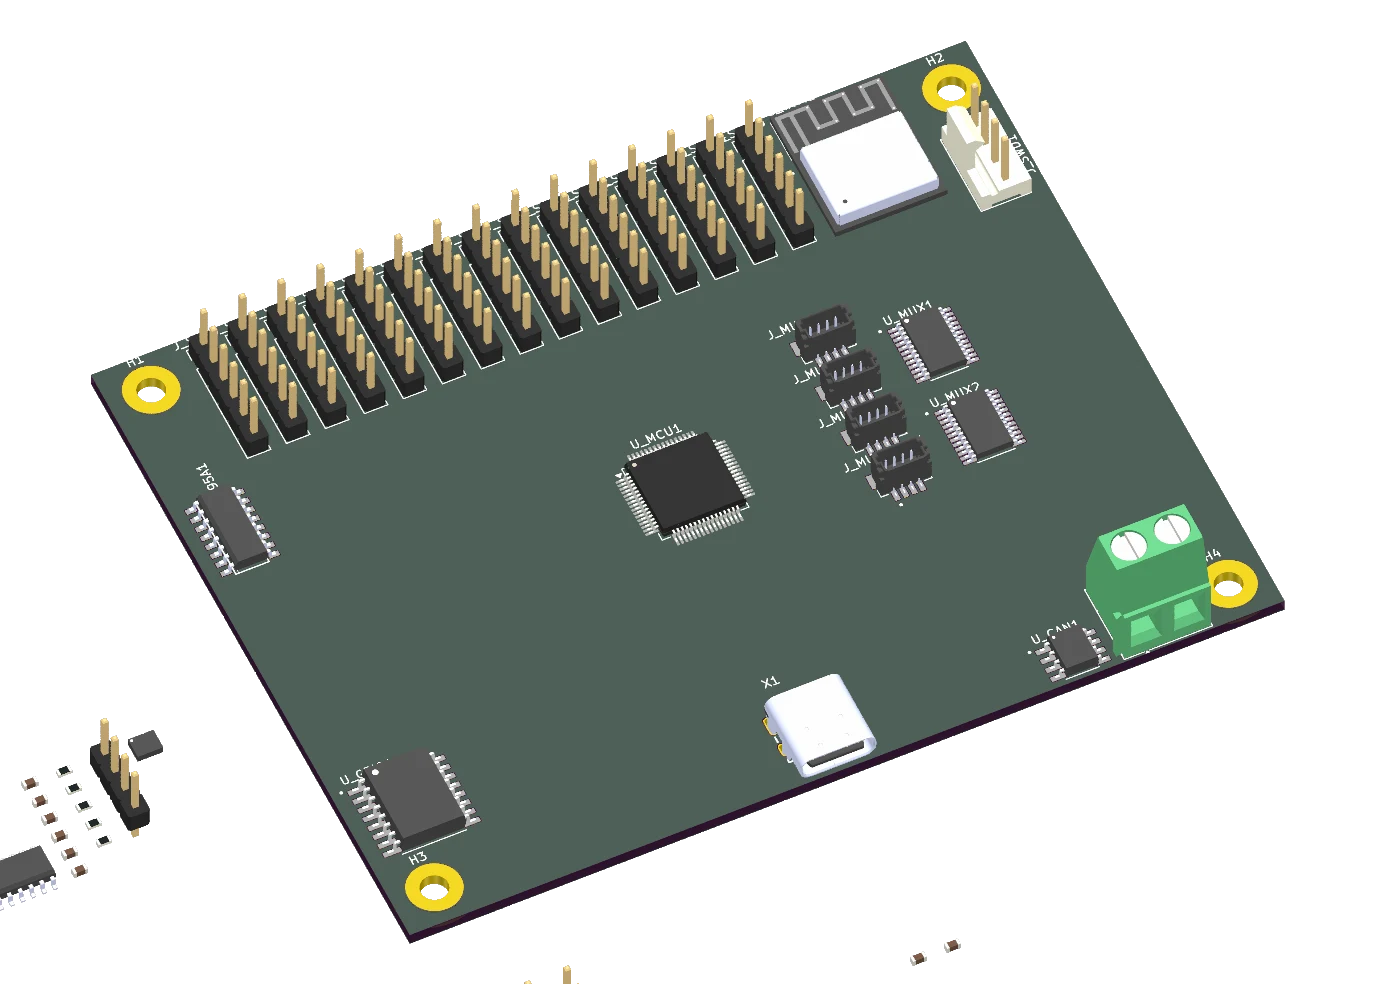
Orbit actual PCBs and mechanical models.
Download the design files and rendered views.
03 / THE WAY I THINK
The most interesting engineering happens where disciplines meet.
I’m studying mechatronics at the University of Canterbury, with a focus on embedded systems, robotics, electronics and engineering software. I enjoy working across the full chain: understanding the physical problem, designing the hardware, writing the control logic and building the tools to see what is actually happening.
That same approach has taken me into aerospace engineering data workflows at Rocket Lab, where I worked on CAD/PLM migration and Python automation used in production.
More about me on LinkedIn ↗Mechanical integration, CAD, prototyping and design iteration.
Custom circuits, PCB design, microcontrollers and firmware.
PID tuning, sensing, telemetry, mapping and navigation tools.
Python automation, numerical analysis and useful desktop interfaces.
04 / BEYOND THE WORKBENCH
Bringing the same curiosity and care
to production workflows and
engineering teams.
Rocket Lab
Returning to Rocket Lab for an integrated operations engineering internship.
Rocket Lab · Auckland, New Zealand
Supported aerospace CAD/PLM migration from SolidWorks / EPDM to Siemens NX and Teamcenter. Built Python tooling for large-scale engineering data workflows used in production.
University of Canterbury · Christchurch, New Zealand
Projects spanning embedded systems, robotics, electronics and structural analysis.
05 / NEXT CONVERSATION
Interested in robotics, embedded systems
or engineering tools? Let’s connect.